I. Overview
Practical training is indispensable for teaching Industrial Robot Application Technology. However, purchasing physical industrial robots and workstation systems for practical training involves high costs, limited quantities, expensive maintenance and large space occupation. This creates a striking conflict between teaching standards and training capacity gaps, so practical training can only be carried out in separate batches and groups.Therefore, deploying an industrial robot virtual- real integrated training system — the Industrial Robot Cloud Teach Pendant System — delivers robot teaching and hands- on training via semi- physical simulation. It overcomes the limitations of training using built- in virtual teach pendants in simulation software: the on- screen virtual teach panel obscures the 3D workstation viewport; operations rely on mouse and keyboard input without tactile feedback such as button resistance and joystick feel from a physical teach pendant. As a result, students cannot build muscle memory for real- robot operation when training this way.By contrast, this system immerses students in industrial scenarios to deliver authentic hands- on experience. Meanwhile, it greatly cuts schools’ capital expenditure on physical robots and workstations. Each student gets a physical teach pendant to program and operate virtual robots, reducing teachers’ workload of guiding separate batch- based training and enabling whole- class synchronized practical training.
II. System Composition and Solutions to Teaching Pain Points
The cloud teach pendant system for industrial robots consists of physical cloud teach pendants, a cloud platform (or on-premises deployment), client software, teaching resources, an AI assistant, and a big-data cloud platform that supports the management of auxiliary teaching processes. Designed for teaching and training on ABB or FANUC industrial robots, it addresses the following pain points in instruction and practical training for majors related to industrial robot technology application:
1. Enables convenient and safe teaching and practical training of industrial robots, lowering teaching difficulty and improving learning efficiency.
2. Resolves the issue of limited physical training equipment, which prevents synchronized group practical training.
3. Supports personalized custom application scenarios, integrates virtual and real simulation for learning and training, and allows seamless handover to physical robot operation.
4. Realizes digital transformation of professional courses for industrial robots.
5. Equipped with an AI assistant to provide intelligent Q&A on knowledge points throughout the learning process.
6. Supports auxiliary teaching process management, enabling real- time monitoring, statistics and tracking of students’ learning progress.
The physical teach pendant imitates the genuine teach pendants of ABB or FANUC industrial robots and interoperates with their dedicated offline programming simulation software. It can program and jog virtual robots within the environment of the dedicated offline programming simulation software, and the compiled programs can be exported for verification in real scenarios.
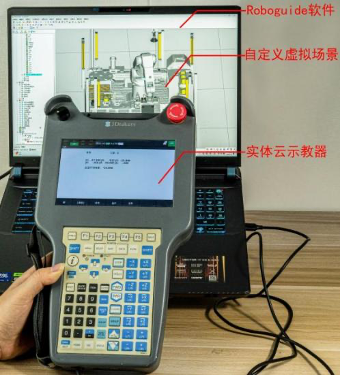
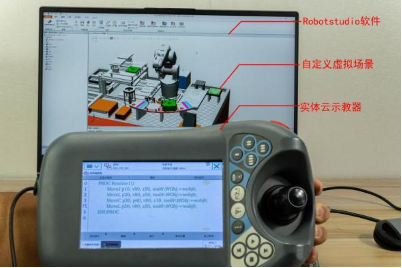
FP-Type Cloud Teach Pendant AP-Type Cloud Teach Pendant
System Environment Requirements:
Training room network: 2.4 GHz WiFi signal;
System operating environment: Windows 10 (64- bit), Windows 11 (64- bit)
III. Product Advantages and Features
(1) The AP- type teach pendant interoperates with RobotStudio, and the FP- type teach pendant interoperates with RoboGuide
Users can learn how to build industrial robot application scenarios and acquire offline programming knowledge using the dedicated offline programming simulation software for ABB or FANUC industrial robots. The physical teach pendant can be connected to perform jog programming and operate virtual robots.
(2) The physical teach pendant interoperates with Siemens Nx MCD
Users can learn the design, planning, digital model creation and simulation of intelligent production lines based on NX MCD. By configuring communication protocols (Modbus TCP / Profinet) between industrial robots and PLCs, control over production- line equipment can be realized. The physical teach pendant can also be connected for jog programming and operation of industrial robots.
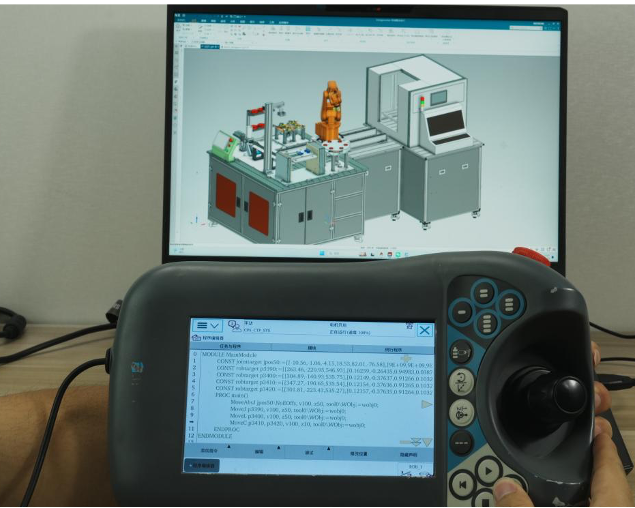
Jog and program ABB robots within the Nx MCD environment
(3) Ease of Product Use
Simply install the supporting software on the user’s computer. The physical teach pendant connects via wireless Wi- Fi for learning robot programming and operation. Teachers and students can practice anytime in classrooms or dormitories with Wi- Fi access, boosting learning efficiency.
(4) Rich Teaching Scenarios Provided
It covers commonly used training projects, including tool coordinate system setup, workpiece/user coordinate system setup, quick- change fixtures, handling, palletizing, path motion, welding, polishing, spraying, comprehensive workstation applications, as well as workstation virtual simulation and commissioning scenarios.
(5) Integration of Simulation- based Teaching and Hands- on Training: Offline Programming, Jog Programming and Virtual Commissioning Consolidated on PC
Simulation teaching and hands- on training for industrial robots can be carried out synchronously using dedicated offline programming software or NX MCD. Users may adopt pre- built virtual scenarios supplied with the system or create custom ones. Offline programming, jog operations and virtual commissioning are all performed on a PC, enabling systematic and coherent teaching and learning.
(6) Seamless Connection to Physical Robot Operation
The integrated and coherent learning combining virtual- real simulation and physical operation meets the learning requirements for students’ skill- level certification examinations. It greatly reduces the cost and difficulty of training, operation, assessment and study, achieving seamless transition to real- robot operation.
(7) Verifiable Learning Outcomes
Programs written on the physical teach pendant can be verified in virtual environments of dedicated offline programming software or Nx MCD, and can also be exported for validation on physical setups.
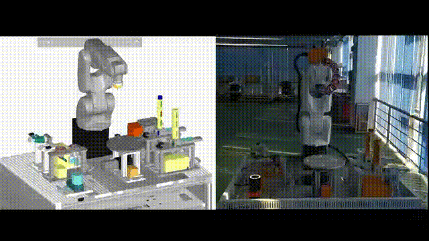
Virtual Environment Verification Real Scenario Verification
(8) Data Acquisition and Control
Through the core CPS control system, real‐ time data of both virtual and physical industrial robots during training can be collected, including equipment status, axis data, joint position data, tool coordinate data, workpiece/user coordinate data, world coordinate data, base coordinate data, program running status, IO status data, etc., which supports the construction of digital twins.
(9) Cloud Teach Pendant Big‐ Data Platform Empowers Teaching Process Management
The big‐ data platform features user management, device management, teaching resources and auxiliary teaching process management. It enables real ‐ time monitoring, statistics and tracking of students’ learning progress, facilitates the learning of industrial robot programming, operation, simulation and commissioning, and empowers higher‐ quality and more efficient teaching.
(10) AI Assistant Built‐ in for Whole‐ process Learning
The AI assistant follows students throughout the learning journey and provides intelligent Q&A. It addresses the challenge that teachers cannot attend to every student simultaneously in class and the delay in problem feedback. With training operation data automatically collected by the cloud platform, it assists teachers in conducting process‐ oriented assessment.
(11) Free OTA Online Upgrade Service Provided
Online upgrades, updates and resource sharing are available to meet users’ new requirements and incorporate newly added course resources.Copyright: © 3Dtakers (Xiamen) Electronic Technology Co., Ltd. 闽ICP备12018448号-3